Designing Dispatch Screens for Robotics
Collaborators
- William Martin Engineering & Design
- Karen Kosasi UI/UX
How I approached designing dispatch screens for a fleet my first time
I had to view the problem as multi-layered. There are 4 constant rules. People set the rules, watch the outcomes and handle what the rules can’t.
Notifications
 Supply Stocker(SS-01) Restocking Lobby Stockroom 62%
 Supply Assistant(SA-01) Fetching Battery Pack 43%
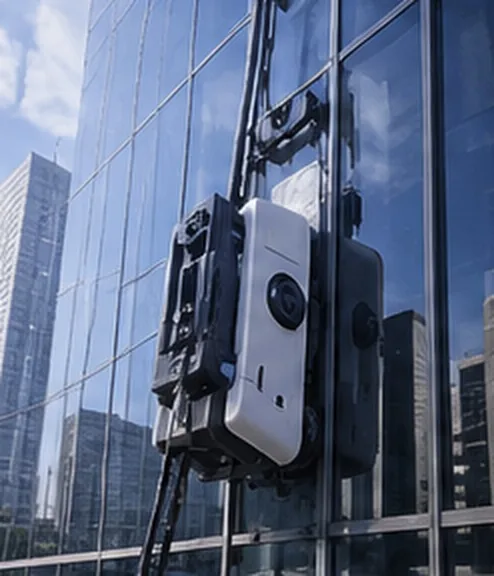
Current Task
Wash East Tower Windows
Est. Completion4 min
Operation Details
- Apply cleaning solution
- Scrub and rinse
- Dry and inspect
Building Zones
- Complete
- In Progress
- Pending
Zones
- East Tower · Floors 29–40Complete
- East Tower · Floors 21–28In Progress
- East Tower · Floors 1–20Pending
- West Tower · Floors 1–402:00 PM
Mission
- Started
- 9:40 AM
- Rail
- Roof track B
- Water
- Deionised
- Next
- West Tower
Panes washed per hour
Consumables
Service
- Next Service
- In 6 days
- Last Service
- 12 days ago
- Faults
- None
- Hours Today
- 2.7 h
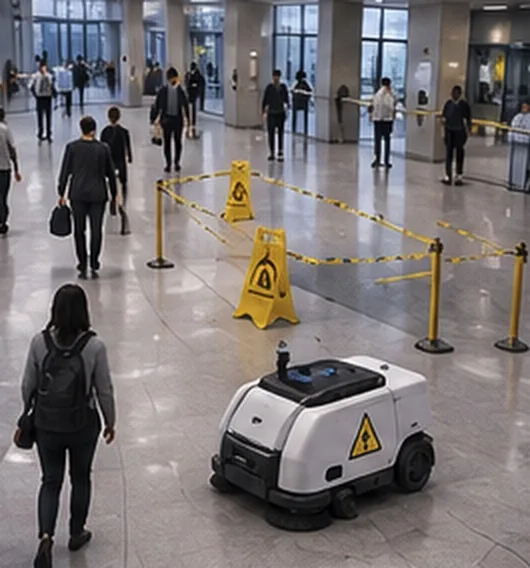
Current Task
Maintain Safe Passage
All ClearMonitoring Paused
Work Zone: Lobby North
Recent Actions
- Placed Wet Floor Signs
- Cordoned Work Area
- Rerouted Foot Traffic
People Flow
Zones
- Lobby NorthWork Zone
- Lobby SouthClear
- Elevator BankClear
- Main Hall EastMonitoring
Work Zone
- Cordon
- 12 m
- Signs Out
- 4
- Cones Out
- 6
- Since
- 10:02 AM
People through Main Hall, every 10 minutes
Activity Log
- Rerouted foot traffic around Lobby North
- Cordoned the work area, 12 m
- Placed 4 wet floor signs
- Arrived at Lobby North
- Left the dock with 6 cones and 4 signs
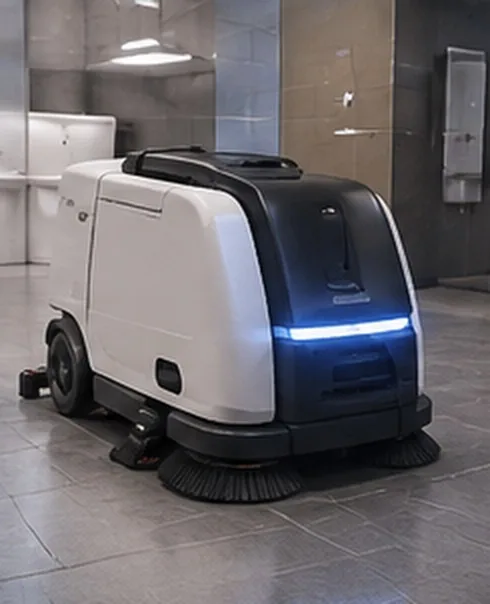
Current Task
Clean Restroom 2F
Est. Completion2 min
Recent Activity
- Area disinfected
- Floors scrubbed
- Waste tank OK
Location
Checklist
- Disinfect surfacesDone
- Scrub floorsDone
- Empty wasteDone
- Restock suppliesIn Progress
- Final inspectionPending
Mission
- Started
- 10:06 AM
- Restroom
- 2F · North
- Next
- Restroom 3F
- Chemistry
- Neutral pH
Restrooms cleaned per hour
Consumables
Service
- Next Service
- In 9 days
- Bags
- 2 left
- Faults
- None
- Hours Today
- 3.1 h
Every button on these screens works. Use the arrows to move between them, or open one full size.Swipe between the screens, then tap one to open it and try the buttons.
01
Route
Which path each robot takes, and who yields at crossings.
02
Assign
Which robot takes which task, weighing distance, battery, capability and load.
03
Sequence
Which task goes first, based on deadlines like the next truck out.
04
Sustain
Charging and maintenance, so enough robots are ready for the next hour.
Swipe or drag the cards to read each rule
The software built to manage these robotic fleets suffered from a fundamental mismatch.
Most fleet management tools were built like logistics dashboards for point-to-point delivery trucks (moving a box from Point A to Point B).
Cleaning and facility robots operate differently in physical space.
They cover areas, not just routes; they run on tight schedules between shifts; and instead of just running out of battery, they run out of clean water, fill up recovery tanks, tangle brushes, and get blocked in congested zones.
How cleaning fleets differ from other robot fleets
Scrubber-dryers that scrub and squeegee, vacuums and sweepers, and trash runners.
| Operating factors | Moving goods | Cleaning floors and hauling trash |
|---|---|---|
| 01The work | A trip from A to B | Covering an area, or a full bin to the compactor |
| 02When | On demand, all shift | Scheduled, often between shifts or overnight |
| 03Success | Throughput against plan | Coverage, quality and proof it happened |
| 04What runs out | Battery | Battery, clean water, dirty-water tank, bags, brushes |
| 05Who tends them | Supervisors and techs | Janitorial or facility staff, often a contractor |
| 06Typical problems | Blocked, lost, faults | Tank full, brush tangled, area busy, zone skipped |
People on the floor
Shift supervisor
Key question
Is the fleet healthy, and where do I need to be?
Device / channel
Console and wall display
Floor associate
Key question
Is this robot here for me, and what do I do with it?
Device / channel
Robot screen, lights, handheld
Maintenance tech
Key question
Which robot, what’s wrong, and where is it?
Device / channel
Handheld or tablet
Operations manager
Key question
Are we on rate for the shift and the week?
Device / channel
Desktop analytics
Vendor support
Key question
What happened, and can I see the logs?
Device / channel
Remote console
When things went wrong, human operators (shift supervisors and maintenance techs) were hit with a flood of generic status updates and cascading alarms. The core design problem wasn’t a lack of data; it was too much noise and no clear hierarchy of meaning.
With robotics, the floor writes the constraints.
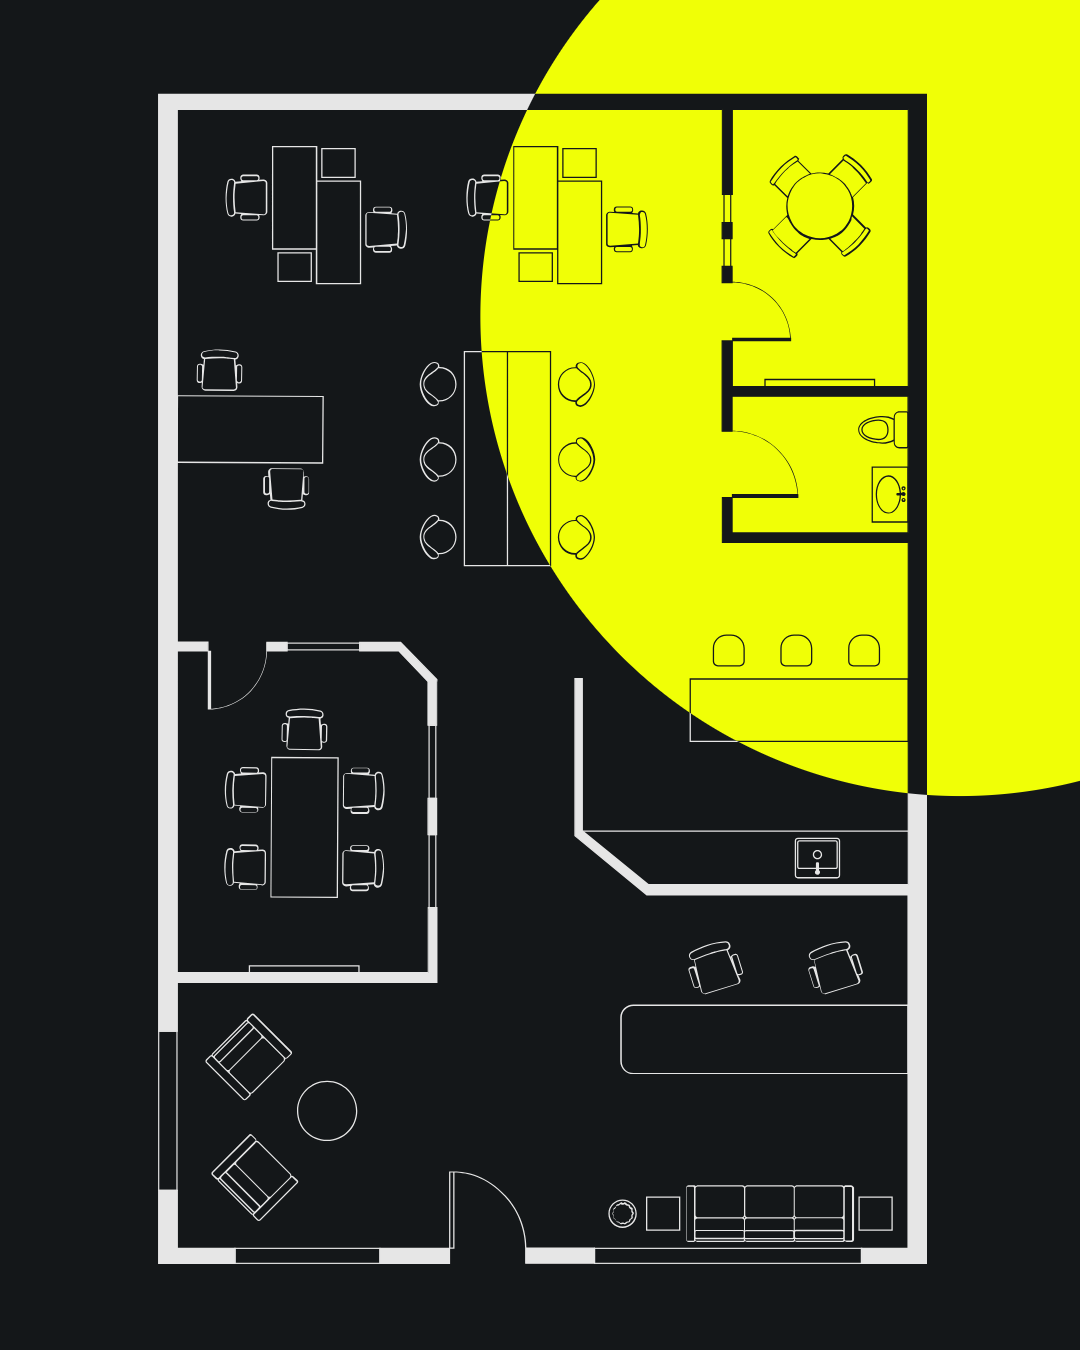
Night-shift console
Cleaning robots need coverage views
S-2 · dirty
tank 85%
Zone D · skipped
Pallets in
aisle, 02:10
- Cleaned
- Skipped
- Robot
- 01
Coverage, not dots. Show what got cleaned, what was skipped and why.
- 02
Consumables as countdowns.
Dirty-water tank full in ~15 minbeats a sudden stop. - 03
Schedule around people. Clean in quiet hours; pause busy areas, and say so.
- 04
Wet floor is a safety state. Show where it’s still damp; keep walkways clear.
- 05
Proof of clean. A morning report for facility managers and contractors.
- 06
One floor, two fleets. Cleaners yield to dispatch traffic; show both on one map.
Level 1
Perceive
What is happening?
Example
R-14 has stopped in aisle C.
Level 2
Comprehend
What does it mean?
Example
R-14 is blocking six robots. Station 3 has no work.
Level 3 · where the value is
Project
What happens next?
Example
At this rate the shift misses target in about 12 minutes.
Borrowed from control rooms
Fundamentals
- Design for meaning and prediction, not just status
- Use color as a signal, not a decoration
- Apply alarm discipline
- Automation should be self-explanatory
- Someone should own each decision
Gray is normal.
Color means trouble.
- R-01Moving
- R-02Station
- R-03Moving
- R-04Charging
- R-05Moving
- R-06Idle
- R-07Station
- R-14Blocked
- R-09Moving
- R-10Moving
- R-11Charging
- R-12Station
Shifting the paradigm: the four rules and industrial calm
To approach this complexity, the design had to pivot from traditional software UI to something inspired by industrial control rooms, specifically high-performance HMI standards like ISA-101 and alarm management guidelines like ISA-18.2.
The system was rebuilt around four constant operational pillars:
01
Route
Which path each robot takes, and who yields at crossings.
02
Assign
Which robot takes which task, weighing distance, battery, capability and load.
03
Sequence
Which task goes first, based on deadlines like the next truck out.
04
Sustain
Charging and maintenance, so enough robots are ready for the next hour.
Swipe or drag the cards to read each rule
To prevent operator burnout, the interface adopted a philosophy of silence:
Gray is normal, and color means trouble.
Muted backgrounds and flat shapes gave the eye nothing to chase when everything was running smoothly.
Saturated color was strictly reserved for anomalies, always paired with explicit text or shape descriptors rather than relying on color alone.
Alarms were treated as literal requests for action, capped at a manageable 6 to 12 per operator per hour to eliminate alert fatigue.
Alarm design principle
An alarm is a request for action
If nobody needs to act, it isn’t an alarm.
Log it as an event.
Every alarm should arrive with three things: its priority, the likely cause, and the recommended response.
Watch for floods: one root cause can trigger dozens of alarms at once. Group them, or people start muting everything.
~6/hr
alarms per operator
Very likely acceptable
~12/hr
alarms per operator
The maximum manageable
ISA-18.2 guidance from the process industries. A starting budget, not a robotics rule.
The view from the robots’ cameras was insightful for understanding the constraints and the environment, as the AI mapped objects and people correctly.
Fleet manager
Promising Results, But a Careful Path Forward
By designing for meaning, prediction, and alarm discipline, early testing showed a dramatic shift. Operators spent less time chasing phantom alerts and more time proactively managing exceptions. The cognitive load dropped, and human-robot collaboration on the floor felt far more intuitive.
Yet, bridging the gap between cutting-edge autonomy and messy, unpredictable physical environments is a delicate process. Today, advanced robotics dispatch and telemetry remain very much in beta. Rather than rushing into massive deployments, systems are being scaled slowly and deliberately, site by site, edge case by edge case, ensuring that safety, reliability, and human trust are hardcoded into every deployment before the next wave rolls out.